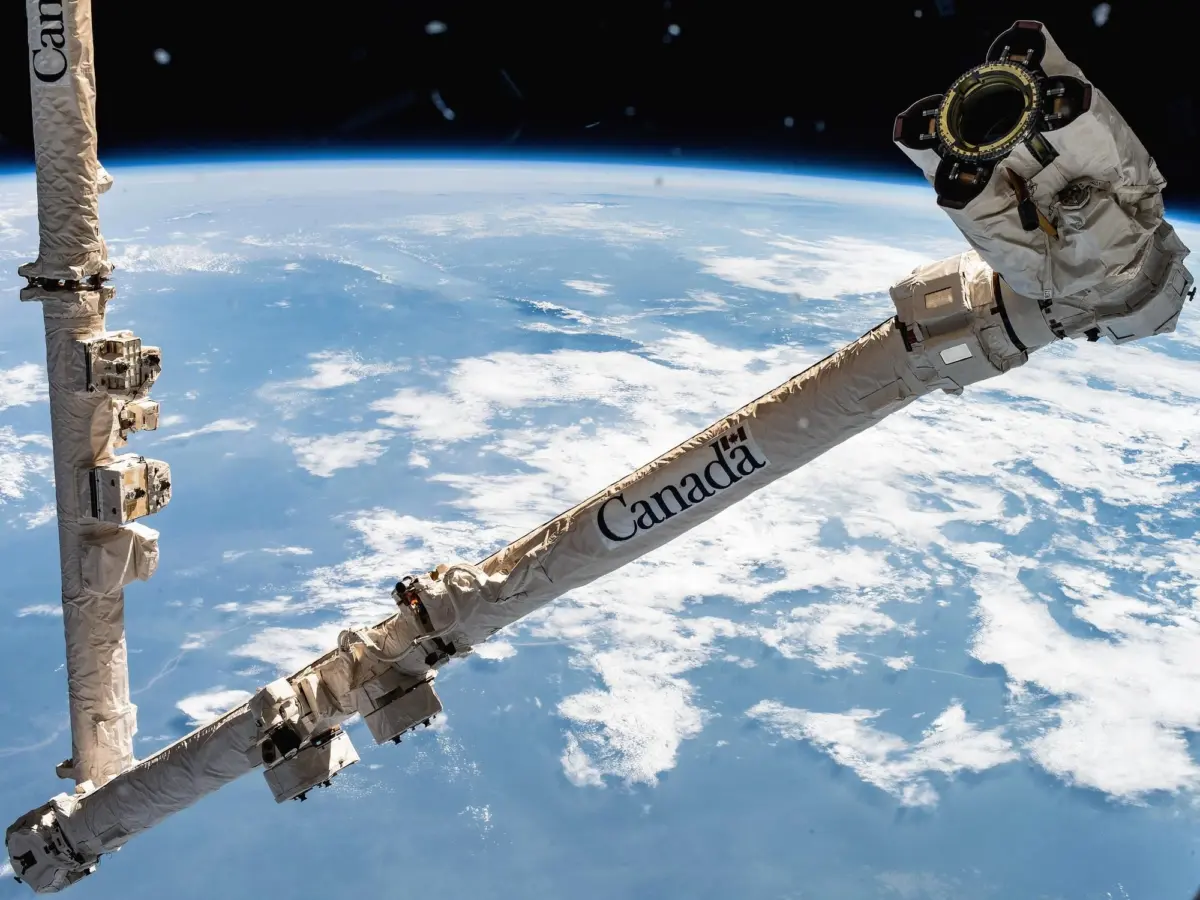
Decades after transforming the landscape of human spaceflight, the pioneering robotic arm that once unloaded payloads from NASA’s space shuttles and helped construct the International Space Station has been officially recognized for its profound engineering legacy. The legendary Shuttle Remote Manipulator System, universally known as the Canadarm, has been dedicated as the 300th IEEE Milestone, cementing its status as one of the most significant technological achievements in aerospace history.
The formal dedication ceremony took place at the headquarters of MDA Space in Brampton, Ontario, bringing together prominent IEEE leaders, aerospace executives, and many of the original engineers, designers, and programmers who brought the revolutionary robotic system to life. Sponsored by the IEEE Toronto Section, the landmark honor celebrates a joint technological triumph shared between the United States and Canada that forever altered how humanity interacts with and operates in the harsh environment of outer space.
"It is entirely appropriate that the 300th Milestone is the Canadarm," said Michael Geselowitz, senior director of the IEEE History and Heritage group. "The technology spans aerospace, robotics, and computing fields of interest. It involves international cooperation between the United States and Canada, and it shows how IEEE and its members are at the cutting edge of many frontiers of science and technology."
Origins in Space Shuttle Efficiency and International Cooperation
The story of the Canadarm begins in the late 1960s, a period when NASA embarked on an ambitious quest to develop a system of reusable space shuttles. The goal was to make space operations significantly more efficient and cost-effective. These revolutionary spacecraft were designed to launch vertically like traditional rockets, maneuver seamlessly in Earth’s low orbit to perform complex missions, and glide back to Earth to land horizontally like conventional airplanes. Crucially, they were built to carry massive satellites and heavy cargo to and from orbit.
However, operating machinery in the rigorous environment of space inevitably brings mechanical challenges. Systems break down, components require routine maintenance, and sensitive payloads must be precisely positioned and transferred to their final destinations. To tackle these complex mechanical challenges, NASA sought international partners for the reusable spacecraft program and officially invited Canada to participate in 1969.
It took Canadian officials several years to determine which specific domestic technology they could contribute to the grand venture. According to the official IEEE Milestone documentation, inspiration ultimately struck when planners learned of a specialized robot designed to load and replace spent nuclear fuel bundles in Canada’s deuterium uranium nuclear reactors. That heavy-duty industrial robot, originally developed by DSMA-Atcon—a firm that is now part of MDA Space—served as the conceptual blueprint for what would eventually evolve into the Canadarm.
In 1974, a formal proposal was submitted to design and build a specialized Shuttle Remote Manipulator System capable of safely unloading the contents of a space shuttle’s cavernous payload bay. NASA approved the ambitious project, and formal development commenced in 1975. Because Canada did not possess a national space agency at the time, the country’s National Research Council stepped in to coordinate the diverse consortium of organizations collaborating on the engineering marvel.
Spar Aerospace took the helm as the lead contractor, heading a multidisciplinary subcontractor team that included DSMA-Atcon, CAE, and the Canadian subsidiary of RCA Corp. Additionally, brilliant engineering minds from the University of Toronto’s Institute for Aerospace Studies provided vital research and development contributions to the undertaking.
Engineering an Advanced Robotic Arm for Zero Gravity
Designing a robotic system destined for outer space presented unprecedented engineering challenges. NASA established rigorous, uncompromising requirements for the robot: the arm had to be exceptionally lightweight and compact enough to fit snugly inside the shuttle’s cargo bay, yet powerful enough to perform heavy lifting. Furthermore, the robot needed to possess full mobility—capable of moving forward and backward, up and down, left and right, and rotating fluidly along three perpendicular axes, a technical specification known as having six degrees of freedom.
To meet these exacting criteria, engineer Peter Carlisle Hughes conceived a brilliant mechanical architecture featuring two distinct shoulder joints, a flexible elbow, and three rotating wrists.
"Each joint had six degrees of freedom, and the arm had six links so that it could grab anything from any angle and move it anywhere," Hughes explained in a retrospective account published by the University of Toronto. Hughes, an IEEE life member who worked closely with the Institute for Aerospace Studies, helped shape a machine that would redefine robotic capabilities.
The resulting robotic arm stretched 15 meters long and weighed approximately 400 kilograms. It was constructed from specialized, high-grade materials chosen specifically for their ability to withstand the punishing environment of outer space, including titanium, stainless steel, and graphite epoxy. Ironically, the structure was so remarkably lightweight that it could not physically support its own weight under Earth’s normal gravitational pull. During testing and assembly at Spar’s Brampton headquarters, the arm had to be carefully supported by air bearings resting flat on the laboratory floor.

To design the human-machine interface, CAE engineers—including IEEE Life Member David A. Weston—crafted the intricate display and control panels, as well as the specialized hand controllers that astronauts would use to monitor and operate the robot from the flight deck.
Because the robotic arm was explicitly engineered to operate in an environment of zero gravity, engineers had to build an entire room dedicated to simulating a weightless setting. A sophisticated computer-based simulation facility was constructed at Spar’s headquarters to evaluate the arm’s controllability using advanced simulation models. Among these was RIGID, an early computer simulation model used to test every structural component of the arm except its flexible properties. It was paired with ASAD—an acronym standing for "all singing, all dancing"—which examined the arm’s complex movements to ensure every joint operated correctly under simulated conditions. Both software models were created by Hughes alongside Spar engineer Andrew A. Goldenberg, who is now a professor emeritus at the University of Toronto. This facility also played a critical role in training astronauts on how to master the controls of the Canadarm before venturing into orbit.
After five years of intense research, design, and rigorous testing, the first flight-ready Canadarm was officially completed. In February 1981, it was formally presented to NASA at the Kennedy Space Center in Cape Canaveral, Florida.
A Historic Flight Record and Legacy in Orbit
The Canadarm made its historic debut in November 1981, deployed during the second orbital test flight of the space shuttle Columbia. Attached securely to the exterior of the spacecraft, the robotic arm provided astronauts with an unprecedented capability to handle and transfer tools, delicate scientific satellites, and massive payloads weighing up to 266,000 kilograms while drawing minimal electrical power. Astronauts monitored the arm’s precise movements through a live video feed transmitted by cameras mounted directly on its wrist and elbow joints, utilizing hand controllers and monitors stationed on the shuttle’s flight deck.
Following the immense success of the initial deployment, NASA ordered four additional systems. Over the course of the 30-year space shuttle program, the robotic arms performed flawlessly across numerous missions, routinely achieving mission-critical objectives and conducting vital inspections and repairs of the spacecraft exterior.
In 2001, the technological lineage continued with the deployment of Canadarm2, which was attached permanently to the International Space Station. Canadarm2 played an instrumental role in assembling the orbiting laboratory piece by piece and continues to serve as an indispensable fixture of the station today, handling routine maintenance tasks and maneuvering incoming cargo and supplies.
The original Canadarm flew its final mission in July 2011 aboard the space shuttle Atlantis, bringing a legendary 30-year operational chapter to a close.
Celebrating the Milestone at MDA Space Headquarters
The recent IEEE Milestone dedication ceremony at MDA Space’s Toronto-area headquarters brought together a multi-generational community of visionaries, engineers, and aerospace leaders. Jill Gostin, the 2026 IEEE president-elect, delivered the opening remarks, emphasizing that the honor was a tribute not merely to a piece of hardware, but to the human ingenuity behind it. She praised the engineers, builders, programmers, and visionaries who steadfastly believed that technology could expand human possibilities and dared to push the boundaries of what humanity could achieve beyond Earth.
To commemorate the momentous occasion, Holly Johnson, vice president of MDA Robotics and Space Operations, and IEEE Life Senior Member David Michelson—chair of the IEEE Communications Society’s Communications History Committee and the official proposer of the Milestone—unveiled a permanent bronze plaque honoring the technology.
"This milestone is a reminder of the privilege we all have at MDA Space—as engineers, designers, builders, operators—to build technology that shapes history," Johnson said during the event. "That same pioneering spirit that drove our team in those early days of space exploration now propels us into a new era as we work to build the infrastructure for the moon and beyond."
The newly unveiled plaque, proudly mounted at MDA Space headquarters, encapsulates the historic weight of the achievement: "In 1981 NASA first deployed a Shuttle Remote Manipulator System aboard the Space Shuttle. Developed by Spar Aerospace (now MDA Space) and the National Research Council of Canada, the Canadarm allowed astronauts to safely and reliably manipulate and transfer heavy payloads outside of the Shuttle, and to conduct inspections and repairs. This robotic system played a key role in the Shuttle and International Space Station programs, and revolutionized human spaceflight."
Approved by the IEEE Board of Directors following a rigorous review by the IEEE History Committee, IEEE Milestones recognize outstanding technical developments from around the world that are at least 25 years old.